Monday, August 20, 2012

View LiDAR LAS files with CloudCompare's ccViewer

I found this new open-source software CloudCompare for 3D point cloud and mesh processing, which comes along with a light weight viewer ccViewer. The interesting thing for LiDAR professionals is that the viewer is compiled with support for reading and displaying LiDAR LAS files. The display performance is pretty good even for large LAS files, but that's just about it for the viewer, other than some basic viewing perspectives and basic display coloring. It only has the ability to color the LiDAR points by classification or by elevation. On the other hand, the source code is available and if you have the time and the inclination, you can fork or contribute to the project and make the software work better with LiDAR LAS files.

Running ccViewer
To run the software, simply double click on the ccviewer.exe executable extracted out from the downloaded binaries as shown below. Note the presence of the libLAS.dll in the extracted folder.


This should open up the ccViewer application window.


Now all that is needed to display LiDAR LAS files is to drag and drop the file onto the ccViewer application window.

The following prompt might appear but simply click OK and the LiDAR point cloud will be displayed.


 For more information, visit the project's web site at http://www.danielgm.net/cc/, where the binaries and souce code for the CloudCompare and the ccViewer software can be downloaded.

Monday, August 13, 2012

Use Gimp to create icon shadows for Google Maps

If you make your own custom Google Maps icons, then it is sometimes necessary to create suitable shadow icons for them. There are a few free online tools to do the job but I thought I would try to use Gimp to do the task. I figured out the basic steps:


  1. Duplicate the custom icon, 
  2. De-saturate and darken the duplicate, 
  3. Scale the duplicate in half vertically and skewed it horizontally, 
  4. Reduce the shadow opacity and make another duplicate shadow layer, 
  5. Refine the shadow layers.
  6. Save the shadow icon


Make a duplicate layer of the custom icon

  1. Start Gimp. Load the custom icon e.g. fair.png.

    Note the dimensions of the custom icon in the title bar at the top; 32 by 32 pixels in this example.
  2. If the Layers pane is not displayed, then press CTRL+L. Select the original icon layer, which is usually labelled as Background.


  3. Click the Duplicate layer icon as shown above.

    A duplicate named Background copy is created.
  4. Click the eye icon for the Background copy layer to turn off the display for that layer.
De-saturate and darken a duplicate layer
  1. In  the Layers pane, select the Background layer.
  2. In the menu bar, select Colors | Hue-saturation.

    The Hue-Saturation dialog box appears.


  3. In the Lightness scroll field, drag the handle to the left. Similarly, drag the Saturation handle all the way to the left. Click OK.

    The layer is grayed and darkened.


Scale vertically by half and skew horizontally by half the shadow layer
  1. Select Layer | Scale Layer.

    The Scale Layer dialog box appears.
  2. Toggle the chain off as shown below. This turns off the constant aspect ratio.


  3. In the Height field, type in half the current height e.g. 16. Click Scale.

    The layer is scaled vertically in half.
  4. Press SHIFT+T.

    The Shear dialog box appears.


  5. In the Shear magnitude X field, type in negative half of the current height e.g. -16. Click Shear.

    The layer is sheared horizontally by half.
Adjust the shadow opacity, location and make duplicate the shadow layer
  1. Select the Move Tool in the tool box or press M. Drag the layer until the layer border is aligned as shown below.

  2. Select Image | Fit Canvas to Layers.

    The canvas is expanded to fit the skewed layer.
  3. In the Layers pane, drag the Opacity scroll handle to reduce the opacity e.g. 25%.

  4. Click the Duplicate icon.

    The shadow layer is duplicated as Background copy#1 layer.
Refine the shadow layers by scaling and blurring
  1. In the Layers pane, select the upper shadow layer e.g. Background copy#1.
  2. Select Layer | Scale Layer.

    The Scale Layer dialog box appears.
  3. Make sure the chain icon is connected. In the Width field, reduce the size by a few pixels e.g. from 48 to 43. Click Scale.

    The upper shadow layer is scaled down while maintaining the aspect ratio.
  4. In the Layers pane, select the lower shadow layer e.g. Background.
  5. Select Filters | Blur | Gaussian Blur.

    The Gaussian Blur dialog box appears.


  6. In the Horizontal and Vertical fields, type in a radius e.g. 5.0. Click OK.

    The lower layer is blurred.


Save the shadow icon
  1. Select File | Save As.

    The Save Image dialog box appears.
  2. In the Name field, type in a name e.g. fair-shadow.png. Click Save.

    The Export File prompt pops up.
  3. Toggle Flatten Image on. Click Export.

    The Save as PNG dialog box appears.


  4. Click Save.

    The shadow icon is saved.


Monday, August 6, 2012

Google Mapplet to show geo-referenced image overlays

In standard desktop GIS software applications, it is a common task to display geo-referenced images. I wanted to be able to do the same using just a modern browser and an Internet connection. So after a few late nights, I completed writing this Google Mapplet to load and display local image files with associated ESRI world files as custom overlays in Google Maps. I had to use the HTML5 FileReader objects so only modern browsers such as Chrome, FireFox, Internet Explorer 10 will work.

  1. To run the mapplet, simply go to the site http://dominoc925-pages.appspot.com/mapplets/geoimage.html.

  2. In the sidebar, click the Import Images button.

    The Import image dialog box appears.

  3. In the Image file field, click the button. Browse and select an image file e.g. C44122a1geo.jpg.
  4. In the World file field, click the button. Browse and select the corresponding ESRI world file e.g. C44122a1geo.jgw.
  5. If the image file is in the non-projected coordinate system, then choose Geographic in the Coordinate system type combo box. If the image file is in a projected coordinated system, then choose Projected.

    Note: the raster image transformation for projected coordinate system to the Google Maps Mercator coordinate system is not very accurate. The positioning would be more accurate if the raster image were already in non-projected or Mercator coordinate system.
  6. If the image file is in a projected coordinate system, then choose the correct projection in the Projection combo box.
  7. In the Geodetic Datum field, choose the horizontal datum of the image file, e.g. WGS84, Global Definition.


  8. Click Start Import.

    The image is loaded and displayed.

    If necessary, click the Fit image or Fit all images buttons in the sidebar to center the map display on the image(s)
    .

  9. Optional. If you want to load more images, then repeat the previous steps 3 to 8.
  10. Click Close.

Monday, July 30, 2012

Geomedia code to get the GRecordset's Connection object

When developing driving GeoMedia type applications, I find it convenient to be able to determine from which database connection a feature record set is from. The following C# code snippet is a private method that given a collection of Connection object and a GRecordset object, it returns the Connection object of the record set; or null if it could not find a match.


using PClient = Intergraph.GeoMedia.PClient;
//...etc...
private PClient.Connection GetRecordSetConnection(PClient.Connections conns, PClient.GRecordset rs)
{
PClient.GFields flds = null;
PClient.Connections conns = null;
PClient.GDatabase db = null;
PClient.Connection conn = null;
 
//Get the recordset's GFields collection object
flds = rs.GFields;
 
//Loop through the GeoMedia documents' list of connections
foreach (PClient.Connection cn in conns)
{
//Ignore closed connections
if (cn.Status != PClient.ConnectionConstants.gmcStatusClosed)
{
//Get the current connection's database object
db = (PClient.GDatabase) cn.Database;
//If the recordset's field database name matches the
//connection's database name, then we have found the right connection object
if (db.Name.Equals(flds[0].SourceDatabase))
{
conn = cn;
break;
}
}
}
//Free up memory used by the GeoMedia COM objects
if (flds != null) 
Marshal.FinalReleaseComObject(flds);
if (conns != null) 
Marshal.FinalReleaseComObject(conns);
if (db != null) 
Marshal.FinalReleaseComObject(db);

return conn;
}

Monday, July 23, 2012

Remove noisy spikes from LiDAR data using SAGA GIS and SRTM data

LiDAR data collected from the field contains noise in the form of spikes or zingers (extremely high or low points) and/or clouds. Typically these erroneous points are reclassified as noise from the point cloud by using high-low filters, median filters or other statistical methods. An example is shown in the screenshot below.


I have in mind using the globally available Shuttle Radar Topography Mission (SRTM) data to form an envelope to filter away the extreme noise points using SAGA GIS. SRTM data can be downloaded from http://www2.jpl.nasa.gov/srtm/.

From the SRTM elevation data, a height value can be added and subtracted to form a volume envelope. Any LiDAR points inside the envelope are valid points while any points outside the envelope are noise. The following illustrates a possible workflow.

Load and reproject an SRTM tile to match the LiDAR data

  1. Start SAGA GIS.
  2. Select Modules | File | Grid | Import | Import USGS SRTM Grid.

    The Import USGS SRTM Grid dialog appears.

  3. Click the Files field. Then click the browse [...] button. Browse and select an SRTM file e.g. N39W084.hgt. Click Open. Click Okay.

    The SRTM data is loaded.

    Note: the SRTM data is in a geographical latitude-longitude coordinate system while the LiDAR data is in a projected coordinate system e.g. UTM 17 North.
  4. Select Modules | Projection | Coordinate Transformation (Grid).

    The Coordinate Transformation (Grid) dialog box appears.

  5. In the EPSG Code | Projected Coordinate Systems field, choose a coordinate system e.g. WGS 84 / UTM zone 17N.
  6. In the Data Objects | Grid system field, choose the SRTM grid system e.g. 0.000833; 1201x 1201y; -84x 39y.
  7. In the Data Objects | Grid system | source field, choose the SRTM grid layer e.g. 01.N39W084.


  8. Click Okay.

    The User Defined Grid dialog box appears.


  9. Click Okay.

    The SRTM grid is reprojected into UTM 17 North.

    Note: there are now two SRTM grid layers with the same name. For clarity, we shall remove the first SRTM grid layer.
  10. In the Data tab of the Workspace pane, select the first SRTM grid layer e.g. 01. N39W084.
  11. Press the mouse right click button. In the pop up menu, select Close.


  12. Click Yes and Okay.

    The original SRTM grid layer is removed.
Load the LiDAR LAS file
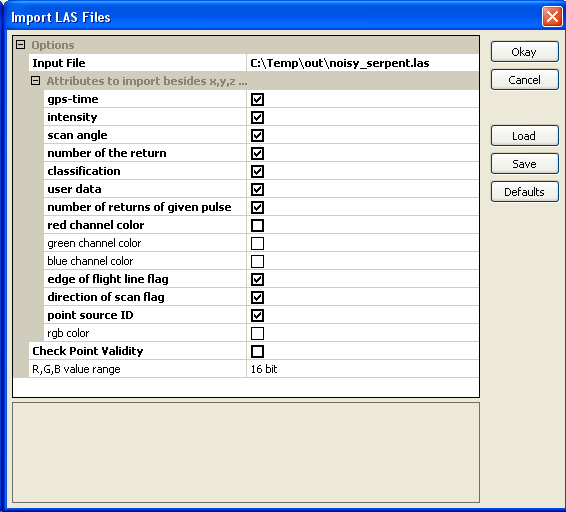
  1. Select Modules | File | Shapes | Import | Import LAS Files.

    The Import LAS Files dialog box appears.
  2. Click the Input file field. Click the browse [...] button and select and open a LiDAR LAS file .e.g. noisy_serpent.las.
  3. In the Attributes to import besides x,y,z list, toggle on all the attributes you want to retain.


  4. Click Okay.

    The LAS file is loaded as a PointCloud.
Assign the SRTM elevations to each LiDAR point
  1. Select Modules | Shapes | Grid | Grid Values | Add Grid Values to Shapes.

    The Add Grid Values to Shapes dialog box appears.
  2. In the Shapes field, choose the LiDAR point cloud layer e.g. 01. noisy_serpent.
  3. In the Grids field, click the [...] button. Choose the reprojected SRTM grid layer e.g. 01.N39W084.


  4. Click Okay.

    The SRTM elevation values are added as a new attribute to the LiDAR point cloud layer.
Create a valid elevation indicator attribute from the LiDAR point and the SRTM elevation values
This part is the key to the workflow. The Calculator is used to create a field that counts two tests: (1) if a point is above the bottom of the SRTM envelope and (2) if a point is below the top of the SRTM envelope. A count of 2 means the point is within the SRTM envelope. 
  1. Select Modules | Shapes | Point Clouds | Tools | Point Cloud Attribute Calculator.

    The Point Cloud Attribute Calculator dialog box appears.
  2. In the Point Cloud field, choose the LiDAR point cloud layer e.g. 01. noisy_serpent.
  3. In the Result field, choose [create].
  4. In the formula field, type in the following (without spaces):

    ifelse(gt(c,n-100),1,0)+ifelse(lt(c,n+100),1,0)

    Note: the point cloud attribute fields are in alphabetical order a, b, c....etc. c indicates the z attribute, n indicates the SRTM elevation field in this example and 100 is half the thickness of the envelope around the SRTM elevation.

    Note: the statement says that if the point z is greater than the bottom of the SRTM envelope (n-100) then assign 1, otherwise assign 0; and if the point z is less than the top of the envelope (n+100), then add another 1. Otherwise add 0.
  5. In the Output Field Name field, type in valid.
  6. In the Field data type field, change to 2 byte signed integer.


  7. Click Okay.

    The Shapes point layer is created with a new attribute field valid containing values 1 and 2.
Filter out the LiDAR points outside the SRTM envelope

  1. Select Module | Shapes | Points | Point Filter.

    The Points Filter dialog box appears.
  2. In the Points field, choose the previously created point cloud layer e.g. 02. noisy_serpent_valid.
  3. In the Attribute field, choose the field created previously e.g. valid.
  4. In the Filtered Points field, choose [create].
  5. In the Filter Criterion field, choose keep maxima (with tolerance). Leave the tolerance at 0.


  6. Click Okay.

    The filtered Shapes point layer 01.noisy_serpent_valid[Filtered] is created. This layer contains only the LiDAR points inside the SRTM envelope.
Save as LAS
Before the filtered points can be saved as a LAS file, the Shapes point layer has to be converted to a point cloud layer. 
  1. Select Module | Shapes | Point Cloud | Conversion | Point Cloud from Shapes.

    The Point Cloud from Shapes dialog box appears.
  2. In the Shapes field, choose the Shapes point layer e.g. 01. noisy_serpent_valid[Filtered].
  3. In the Z Value field, choose Z.
  4. In the Output field, choose all attributes.


  5. Click Okay.

    The Shapes point layer is converted to a point cloud layer 03. noisy_serpent_valid[Filtered].

  6. Select Modules | File | Shapes | Export | Export LAS Files.

    The Export LAS Files dialog box appears.
  7. In the Point Cloud field, choose the filtered point cloud layer e.g. 03. noisy_serpent_valid[Filtered].
  8.  For each LAS field to export out, change the [not set] value to the appropriate attribute field.
  9. If necessary, enter values in the Offset X, Offset Y fields that match the original LAS file.
  10. Optional. Change the Point Data Record field accordingly e.g. to version 2.
  11. In the Output field, define the output file name e.g. clean_serpent.las.


  12. Click Okay.

    The filtered output LAS file is created without the zingers.